Driving Simulator and Visual Simulation Systems
Driving Simulator and Visual Simulation Systems consist of driver-in-the-loop (DIL) driving simulators, visual rendering and simulation environment software, data reinjection systems and simulation data conversion toolchains for the development, validation and testing of intelligent driving and ADAS.
Ansible Motion 驾驶模拟器系列产品
The Ansible Motion Delta S3 dynamic driving simulator is a driver-in-the-loop (DIL) testing system that forms a closed loop with a real driver, virtual vehicle and virtual scenario, realistically simulating vehicle states in various scenarios through visual, motion, haptic feedback and sound effects, and supporting drivers in subjective performance evaluation of the test subject.
Product Features
·High-fidelity driving simulation: supports high-dynamic motion, low-latency feedback and realistic cockpit interaction, providing a driving experience close to a real vehicle
·Six-degree-of-freedom motion platform: supports pitch, roll, yaw, heave and longitudinal/lateral motion, meeting the simulation needs of complex driving conditions
·Immersive visual system: supports large field-of-view, high-resolution surround-screen display, expandable with VR/AR and rear-view display
·Software and model compatibility: supports integration of scenario rendering, vehicle dynamics, traffic participant and sensor simulation tools
·Realistic cockpit and haptic feedback: supports steering wheel, pedals, gear shift, instrumentation and high-frequency haptic feedback, enhancing the authenticity of driving evaluation
·Virtual testing and validation: supports function testing and validation of tires, chassis, powertrain, ADAS, active safety and HMI
Product Images


rFpro 视景渲染软件
rFpro is a high-fidelity simulation environment software designed for the development and validation of autonomous driving and ADAS systems. It builds a reproducible and scalable 'ground truth' level virtual world through millimeter-level accuracy digital road models based on real LiDAR scans, together with a physically accurate ray-tracing rendering engine. rFpro accurately simulates the physical characteristics and signal outputs of sensors such as cameras, LiDAR and radar, providing support for algorithm testing, sensor fusion and V2X validation.
Its core value lies in safely, efficiently and repeatably bringing large-scale, hazardous or hard-to-reproduce real-world driving scenarios into the laboratory, thereby accelerating the R&D cycle of intelligent vehicles and supporting comprehensive functional safety validation.
Product Features
·Scenario library and efficient scenario generation: supports parametric scenarios and batch runs covering corner cases; configurable behavior models and interaction rules for other traffic participants, for complex traffic situations
·High-fidelity digital twin and sensor fidelity: builds road geometry, lane lines, signs and markings from real collected data to achieve a 'digital twin' environment consistent with real roads; performs consistent modeling of time, weather, lighting, shadow and reflection to evaluate perception robustness under different environmental conditions; supports generation of data streams close to real sensor outputs for cameras, LiDAR and millimeter-wave radar, facilitating closed-loop algorithm validation
·Closed-loop testing for autonomous driving: suitable for batch validation of typical ADAS/AD scenarios such as AEB, ACC, LKA, lane change, merge/diverge and intersections; consistent results are reproducible under the same scenario and same random seed, facilitating regression testing and issue localization; running planning/control algorithms in simulation, where vehicle behavior feeds back into scenario evolution, forms a 'perception-decision-control-environment feedback' closed-loop validation
·Unified autonomous driving development platform: supports debugging, training and testing of perception, decision, planning and control algorithms within the same platform
·High-fidelity sensor simulation: integrates high-precision sensor models such as cameras, LiDAR and millimeter-wave radar, supporting sensor fusion testing
·Synthetic training data generation: automatically generates engineering-level annotated data, improving training data production efficiency and reducing cost
·Real digital twin environment: based on real road digital twins and ray-tracing rendering, providing high-quality training and testing scenarios
·Scenario management and generalization testing: supports OpenSCENARIO and OpenDRIVE, enabling quick configuration of weather, traffic, pedestrians and edge-risk scenarios
·Closed-loop algorithm validation: supports complete closed-loop testing from virtual sensor perception to decision planning and vehicle control
·Large-scale parallel simulation: compatible with cloud HPC, enabling parallel execution of large batches of driving scenarios to validate long-term performance and stability
·HIL / SIL / DIL testing support: supports hardware-in-the-loop, software-in-the-loop and driver-in-the-loop testing, covering algorithm development to human-machine collaboration evaluation
·Sensor configuration optimization: supports parallel testing of hundreds of sensors, facilitating optimization of sensor layout and configuration schemes
·L2/L3 autonomous driving validation: suitable for L2/L3 autonomous driving function development, edge scenario testing and user experience optimization
Product Images


HORAE 数据回注系统
The ASEva Pro data reinjection system re-inputs bypass-acquired data into the system under test for simulation or post-processing, and is used to verify and optimize algorithms. Data replay enables this data to play a key role in algorithm verification, model training and system optimization, helps improve the reliability and stability of the system, and accelerates the R&D process.
Product Features
·Algorithm verification and optimization
·Model training
·System debugging and iteration
·Maximized data utilization
Product Images

ASEva 仿真数据转换工具链
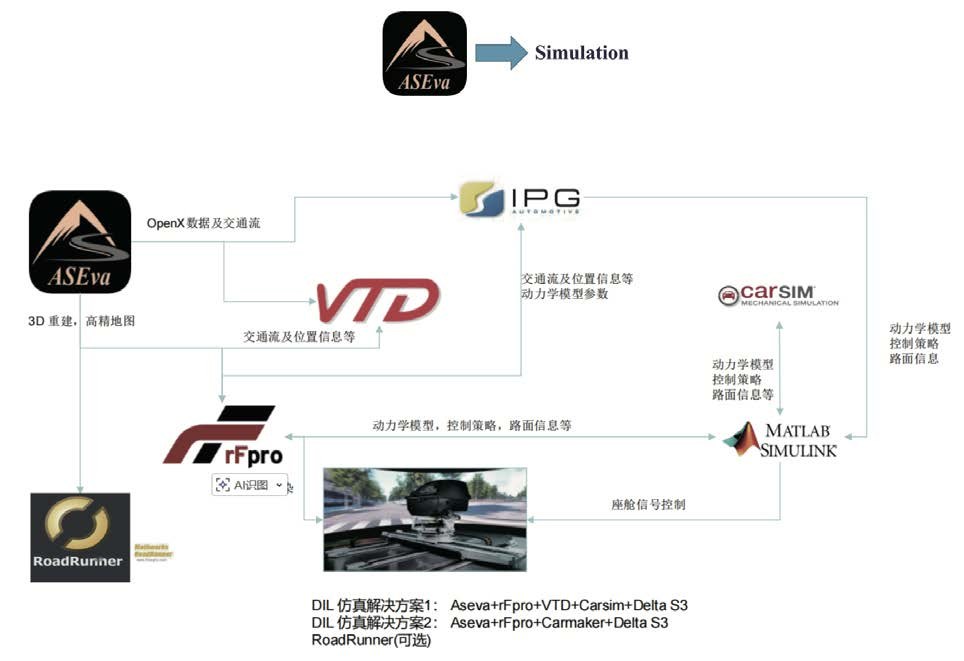
The ASEva Simulation Data Conversion Toolchain is a full-process solution integrating scenario data acquisition, data preprocessing, automated data labeling, data format conversion and virtual simulation batch testing. Designed for autonomous driving and ADAS (Advanced Driver Assistance System) R&D teams, it aims to improve the efficiency and generalization capability of algorithm development, reduce the time and cost of field testing, and support the safety and stability of autonomous driving systems in different scenarios.
Product Features
·Full-process data chain: covers data acquisition, preprocessing, standardization, labeling and extraction, cleaning, scenario validation, scenario generalization, open standard format (OpenX) output and simulation validation across all stages
·Data management and post-processing: supports unified management, cleaning and post-processing of collected data
·Automated data labeling: supports automated labeling and extraction, reducing manual labeling costs
·Scenario generalization and open standard format: supports scenario validation and scenario generalization, and can output OpenX open standard format data
·Simulation toolchain ecosystem: can interface with simulation tools such as rFpro, VTD, CarSim, CarMaker, MATLAB/Simulink and RoadRunner, exchanging data including traffic flow and position information, dynamic models, control strategies and road surface information
·DIL simulation solution: supports building driver-in-the-loop simulation schemes such as ASEva+rFpro+VTD+CarSim+Delta S3 and ASEva+rFpro+CarMaker+Delta S3, realizing cockpit signal control and closed-loop simulation